(01)“For robotics researchers”
Collect sim teleop data with a shareable link.
 e
(02)“Founding research partners”
02For robotics researchers
Your sim,playablein VR.
Share one link. Pilots just need a VR headset and wifi.
No installNo accountQuest Browser
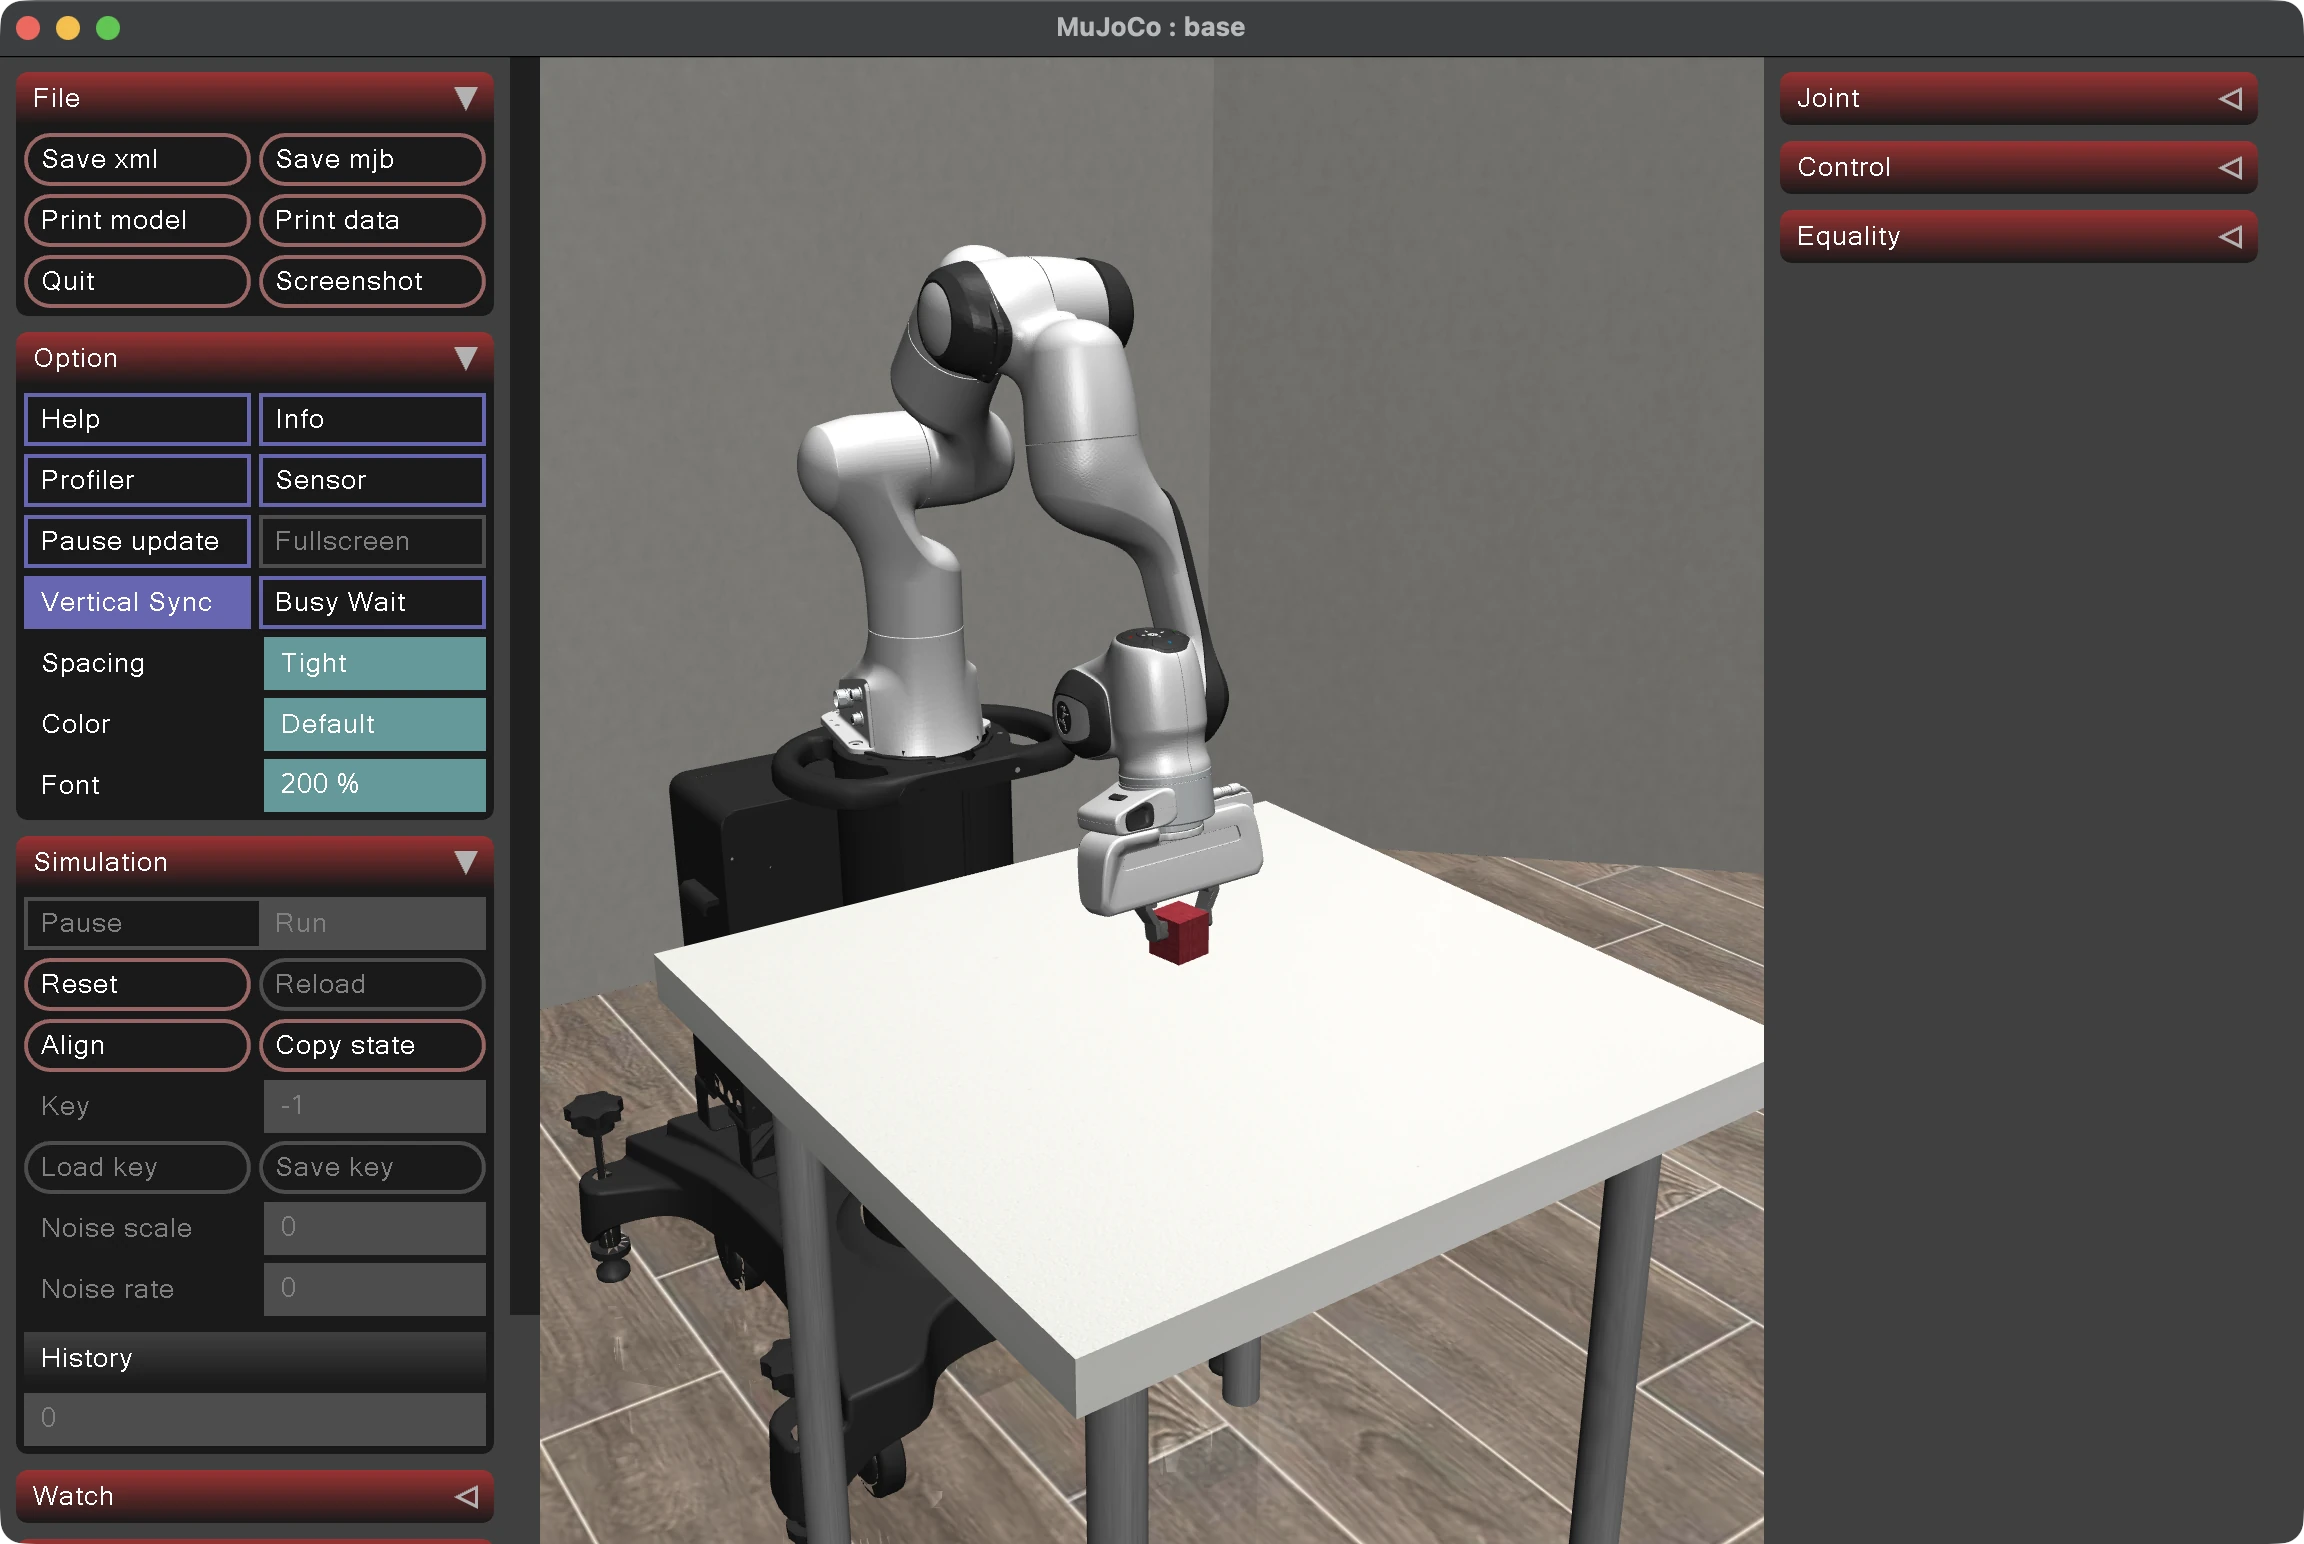
 lift.pyYour sim
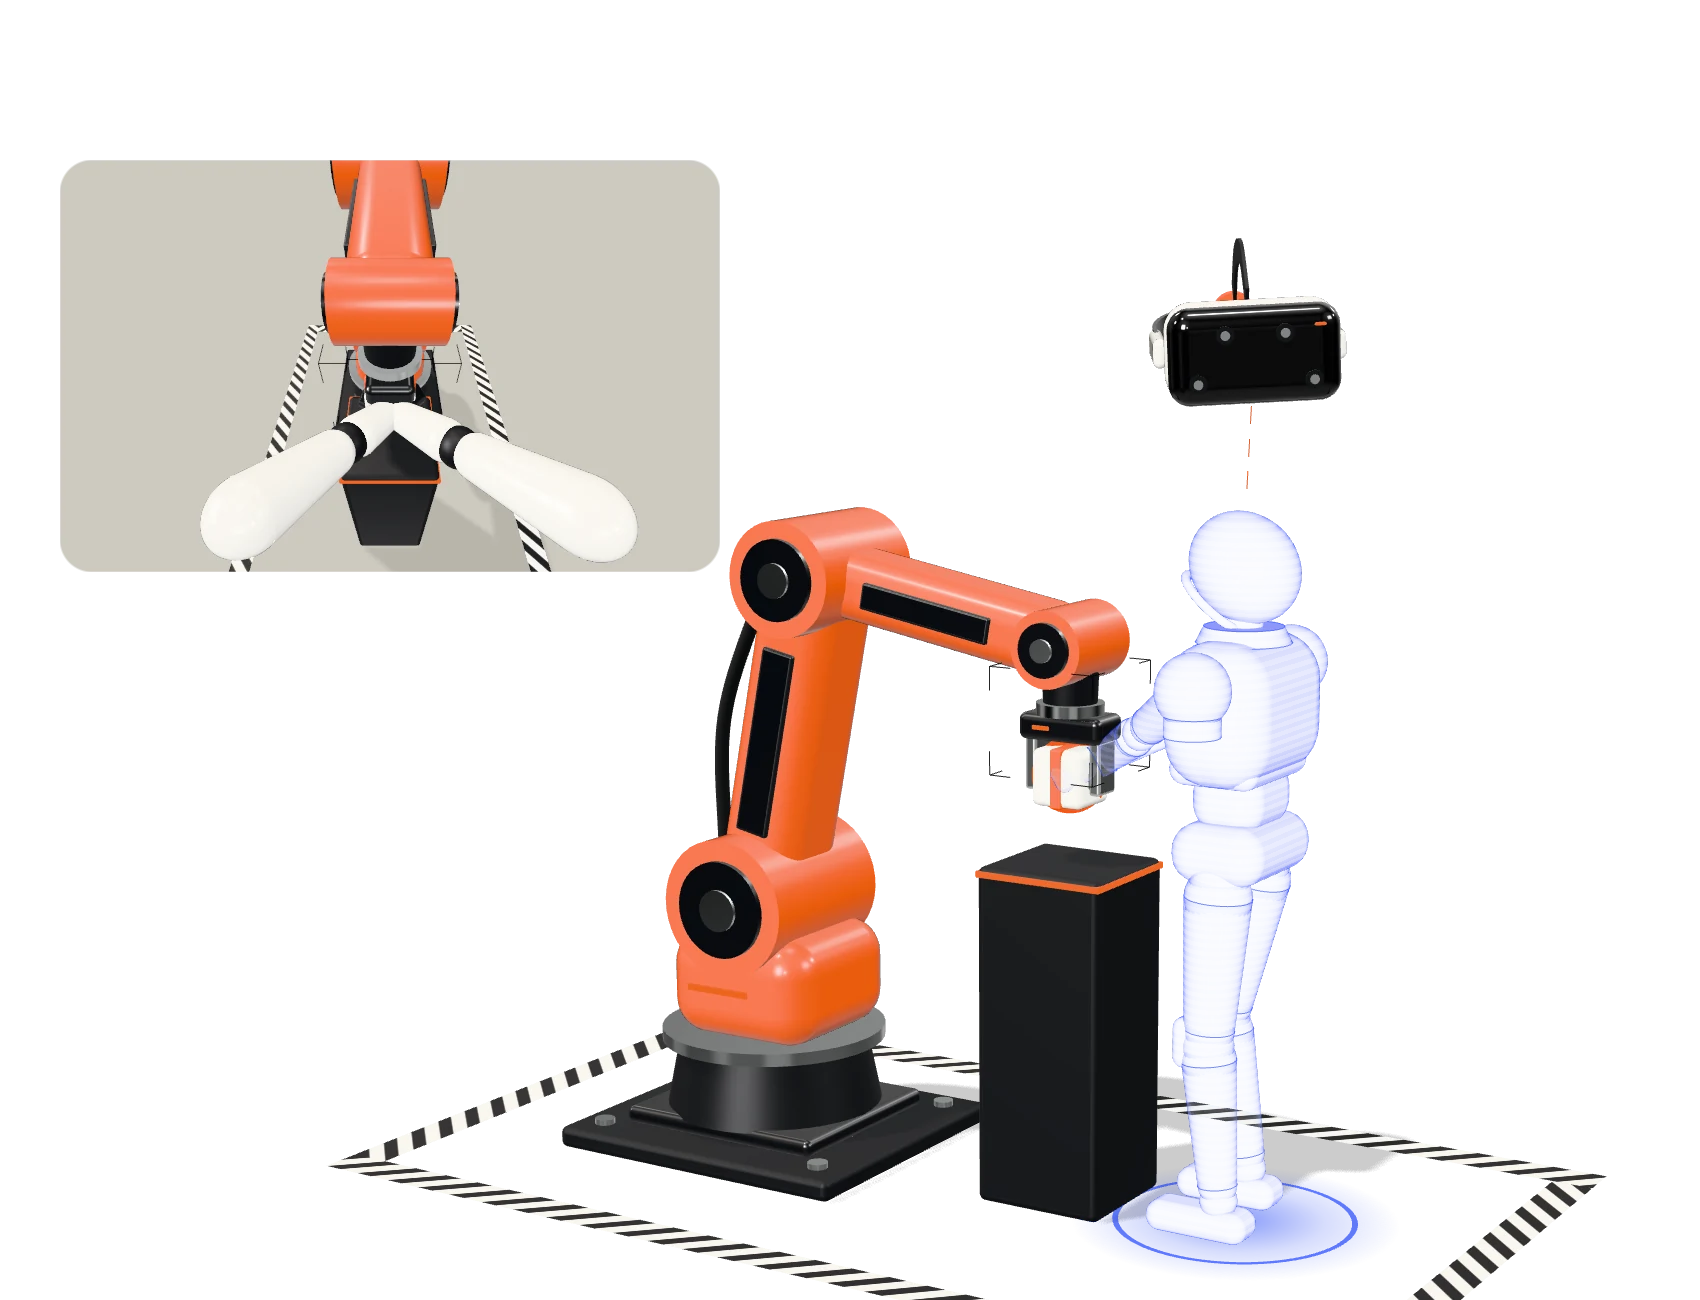 “Pilot” · @kay
Successep_0142 · saved to successes
- Grasp the cube
- Lift it clear
- Hold it at the goal
Lift the cube
(03)“How it works”
03From your laptop to their headset
Bring your sim.Publish it.Share the link.
robosuite on MuJoCo first. Our SDK adds VR controls; your physics and task rules stay yours.
One command uploads it. We build, check and host it in the cloud.
Try it in your own headset, then publish it privately.
Pilots just need a VR headset and wifi. It opens in Quest Browser: no install, no account.
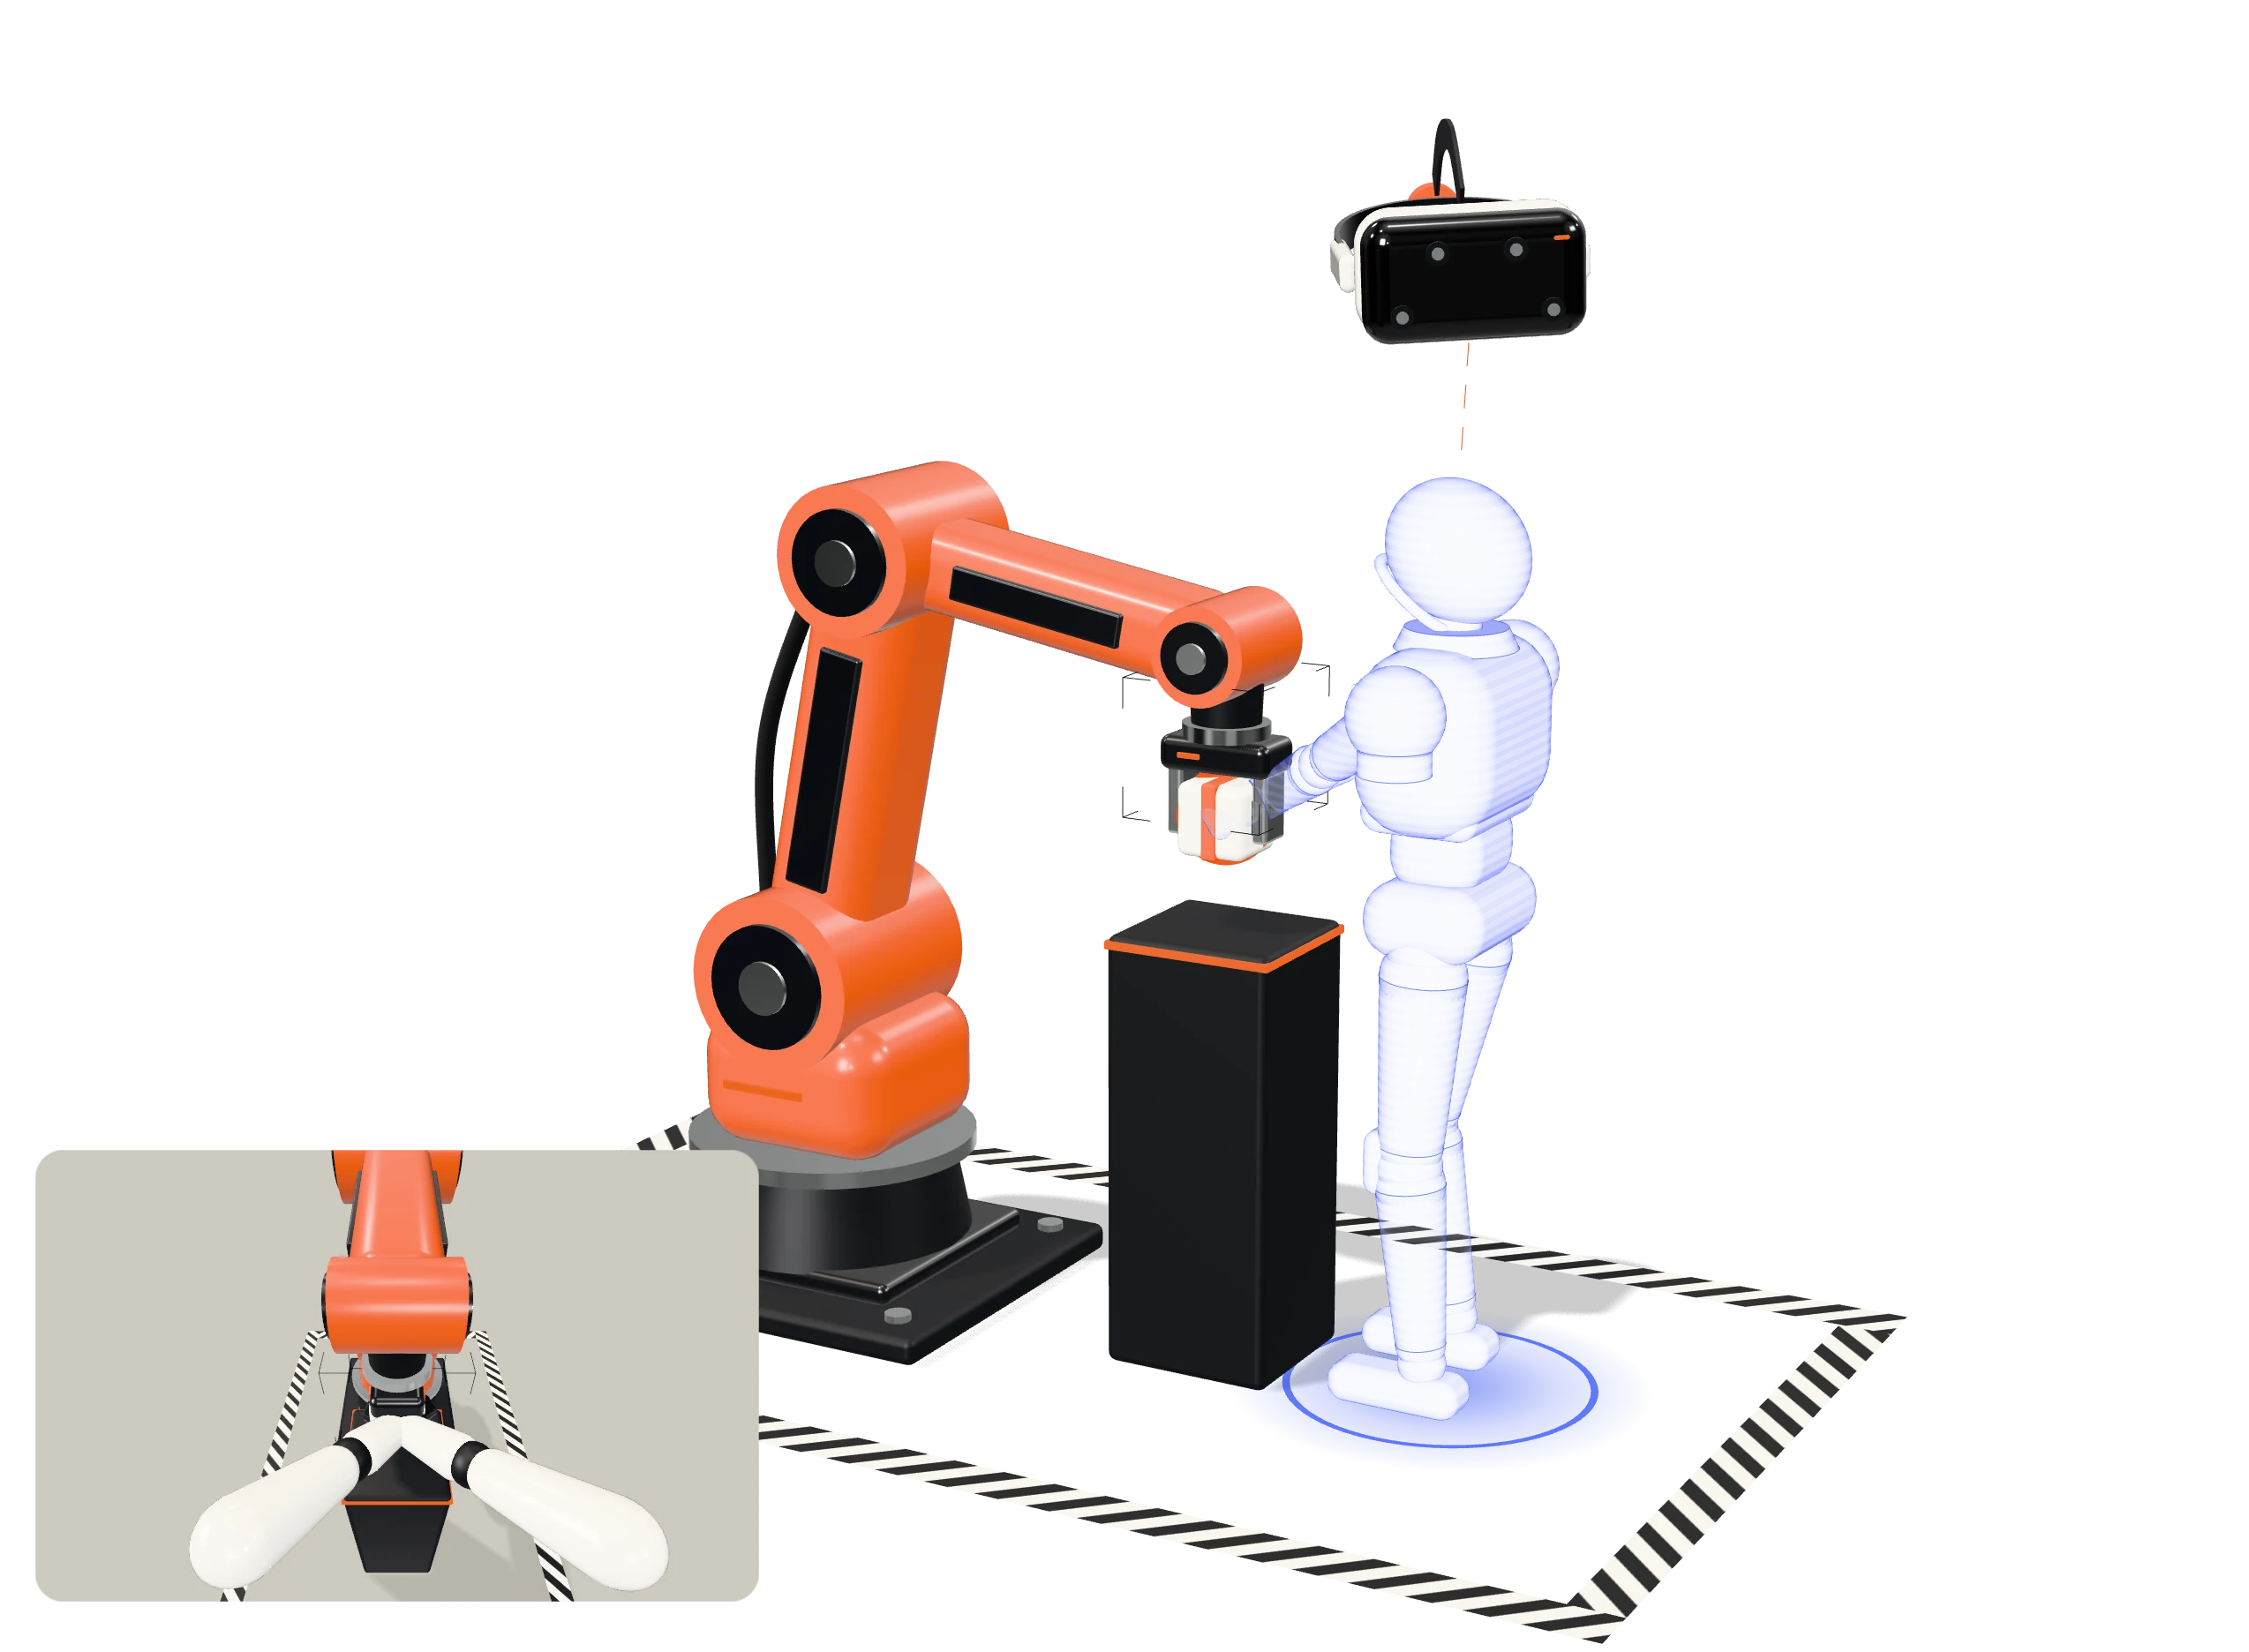 + VR grab target
sample recording · automatic
“Preview” · you
“Pilot” · @kay
Successep_0142 · saved to successes
$ herbie sim init --entry my_project.env:make_env
✓found Lift · Panda · robosuite on MuJoCo
herbie.toml[exports.lift]entry = "my_project.env:make_env"profile = "robosuite-arm-v1"
viewer · lift.pyYour sim+ VR controlsadded by the SDK
- Hand posemoves the gripper · OSC
- Triggercloses the gripper
- Menustart and reset the task
$ herbie sim prepare
- ✓uploadedlift_panda/ · 38.4 MB
- ✓builtuv.lock · in the cloud
- ✓controlshand → gripper
- ✓visualsheadset scene
- ✓recordingsample episode · saved
- startclean reset
- graspcube held
- liftcube +0.18 m
- successtask reports success
Hostedlift_panda v3
- Cloud runtimebuilt from your repo
- One machine per sessionisolated, started on join
- Episodes storedchecked · replayable
Ready to preview
✓Tried in your headsetcontrols · visuals · reset
$ herbie sim publish
PublishPublished · unlisted- Controls feel right
- Task resets cleanly
- Visuals look right
Release v3your limits
- Visibility
- Unlisted · link only
- Sessions
- 1 per pilot
- Expiry
- 24 h
- Spend
- Capped
Revoke any time
- @kayjoined · Quest 3
- @mojoined · Quest 3S
- @linjoined · Quest 3
- Grasp the cube
- Lift it clear
- Hold it at the goal
Episodescoming in
- Successep_0142@kay
- Successep_0143@mo
- Failureep_0144@lin
Sorted · replay · download
(04)“We collect and classify”
04We auto-collect and classify
Every attempt, recorded.Sorted by your own check.
Every attempt is saved in full and sorted into successes and failures by your task's own success check. Replay any episode, or download the dataset.
PlannedLeRobot exportRendered camera viewsMore robot types
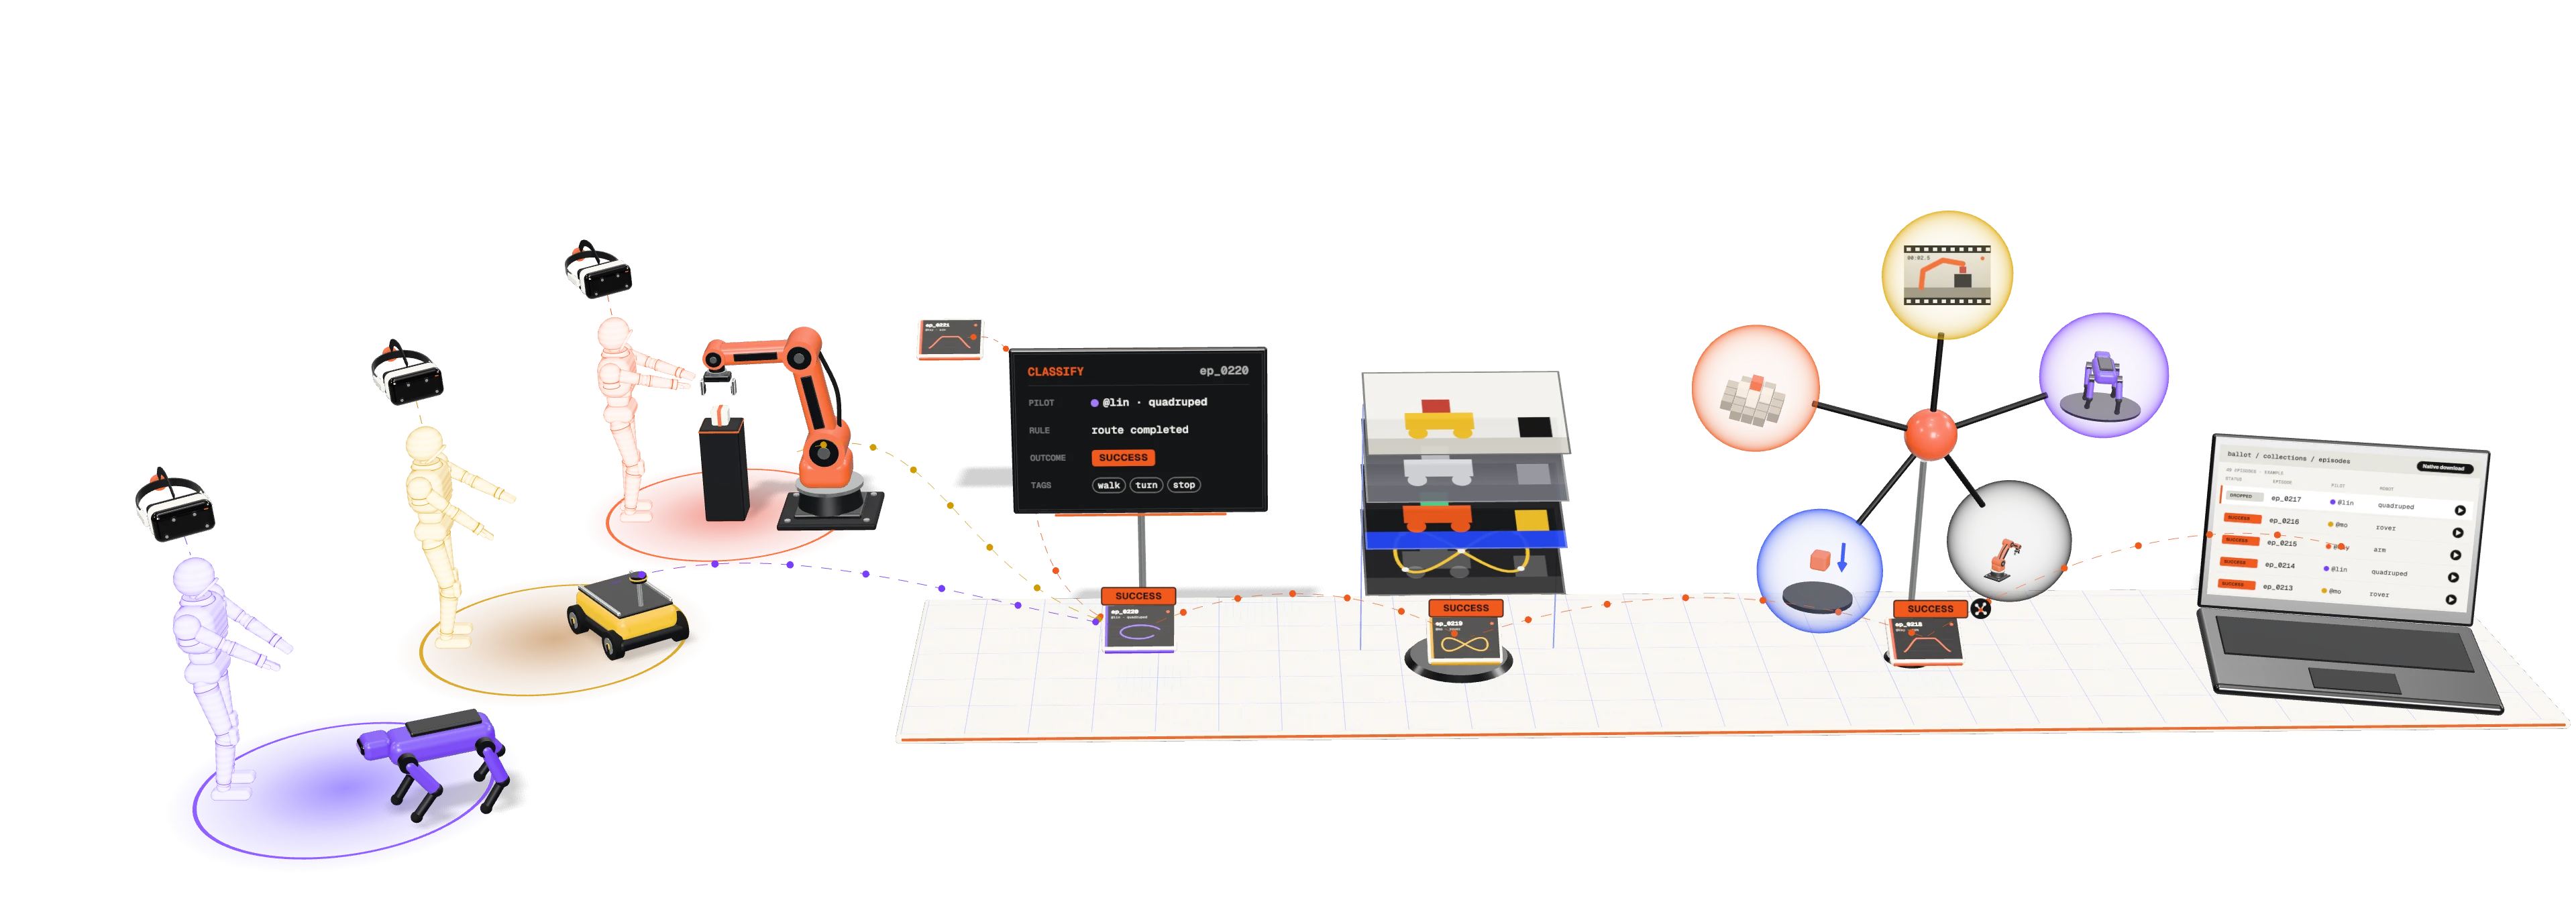 @kayQuest 3 · LiftRec
@moQuest 3S · LiftRec
@linQuest 3 · LiftRec
01“Recorded in full”every attempt · automatic
02“Sorted by your check”your task's own success check
03“Replay”in the browser · any time
04“Download”the full native episodes
pilot commands
applied actions
full sim state
events + outcome
138successes
32failures
ep_0218
In every episodeprovenancestart statepilot commandsapplied actionsfull sim stateevents + outcome
DemonstratedSept 2026 prototype: a human Quest pilot completed Lift and Can; records passed checks; replay ran after the runner stopped. Pipeline feasibility, not learned performance.
(05)“Your task”
05Early access · let's talk
Got a sim thatneeds teleop data?
We're opening early access to a few research teams. Tell us your task.
No commitment. Just a conversation.
Join the waitlistearly access · two minutes Read the docshow it works, in depth
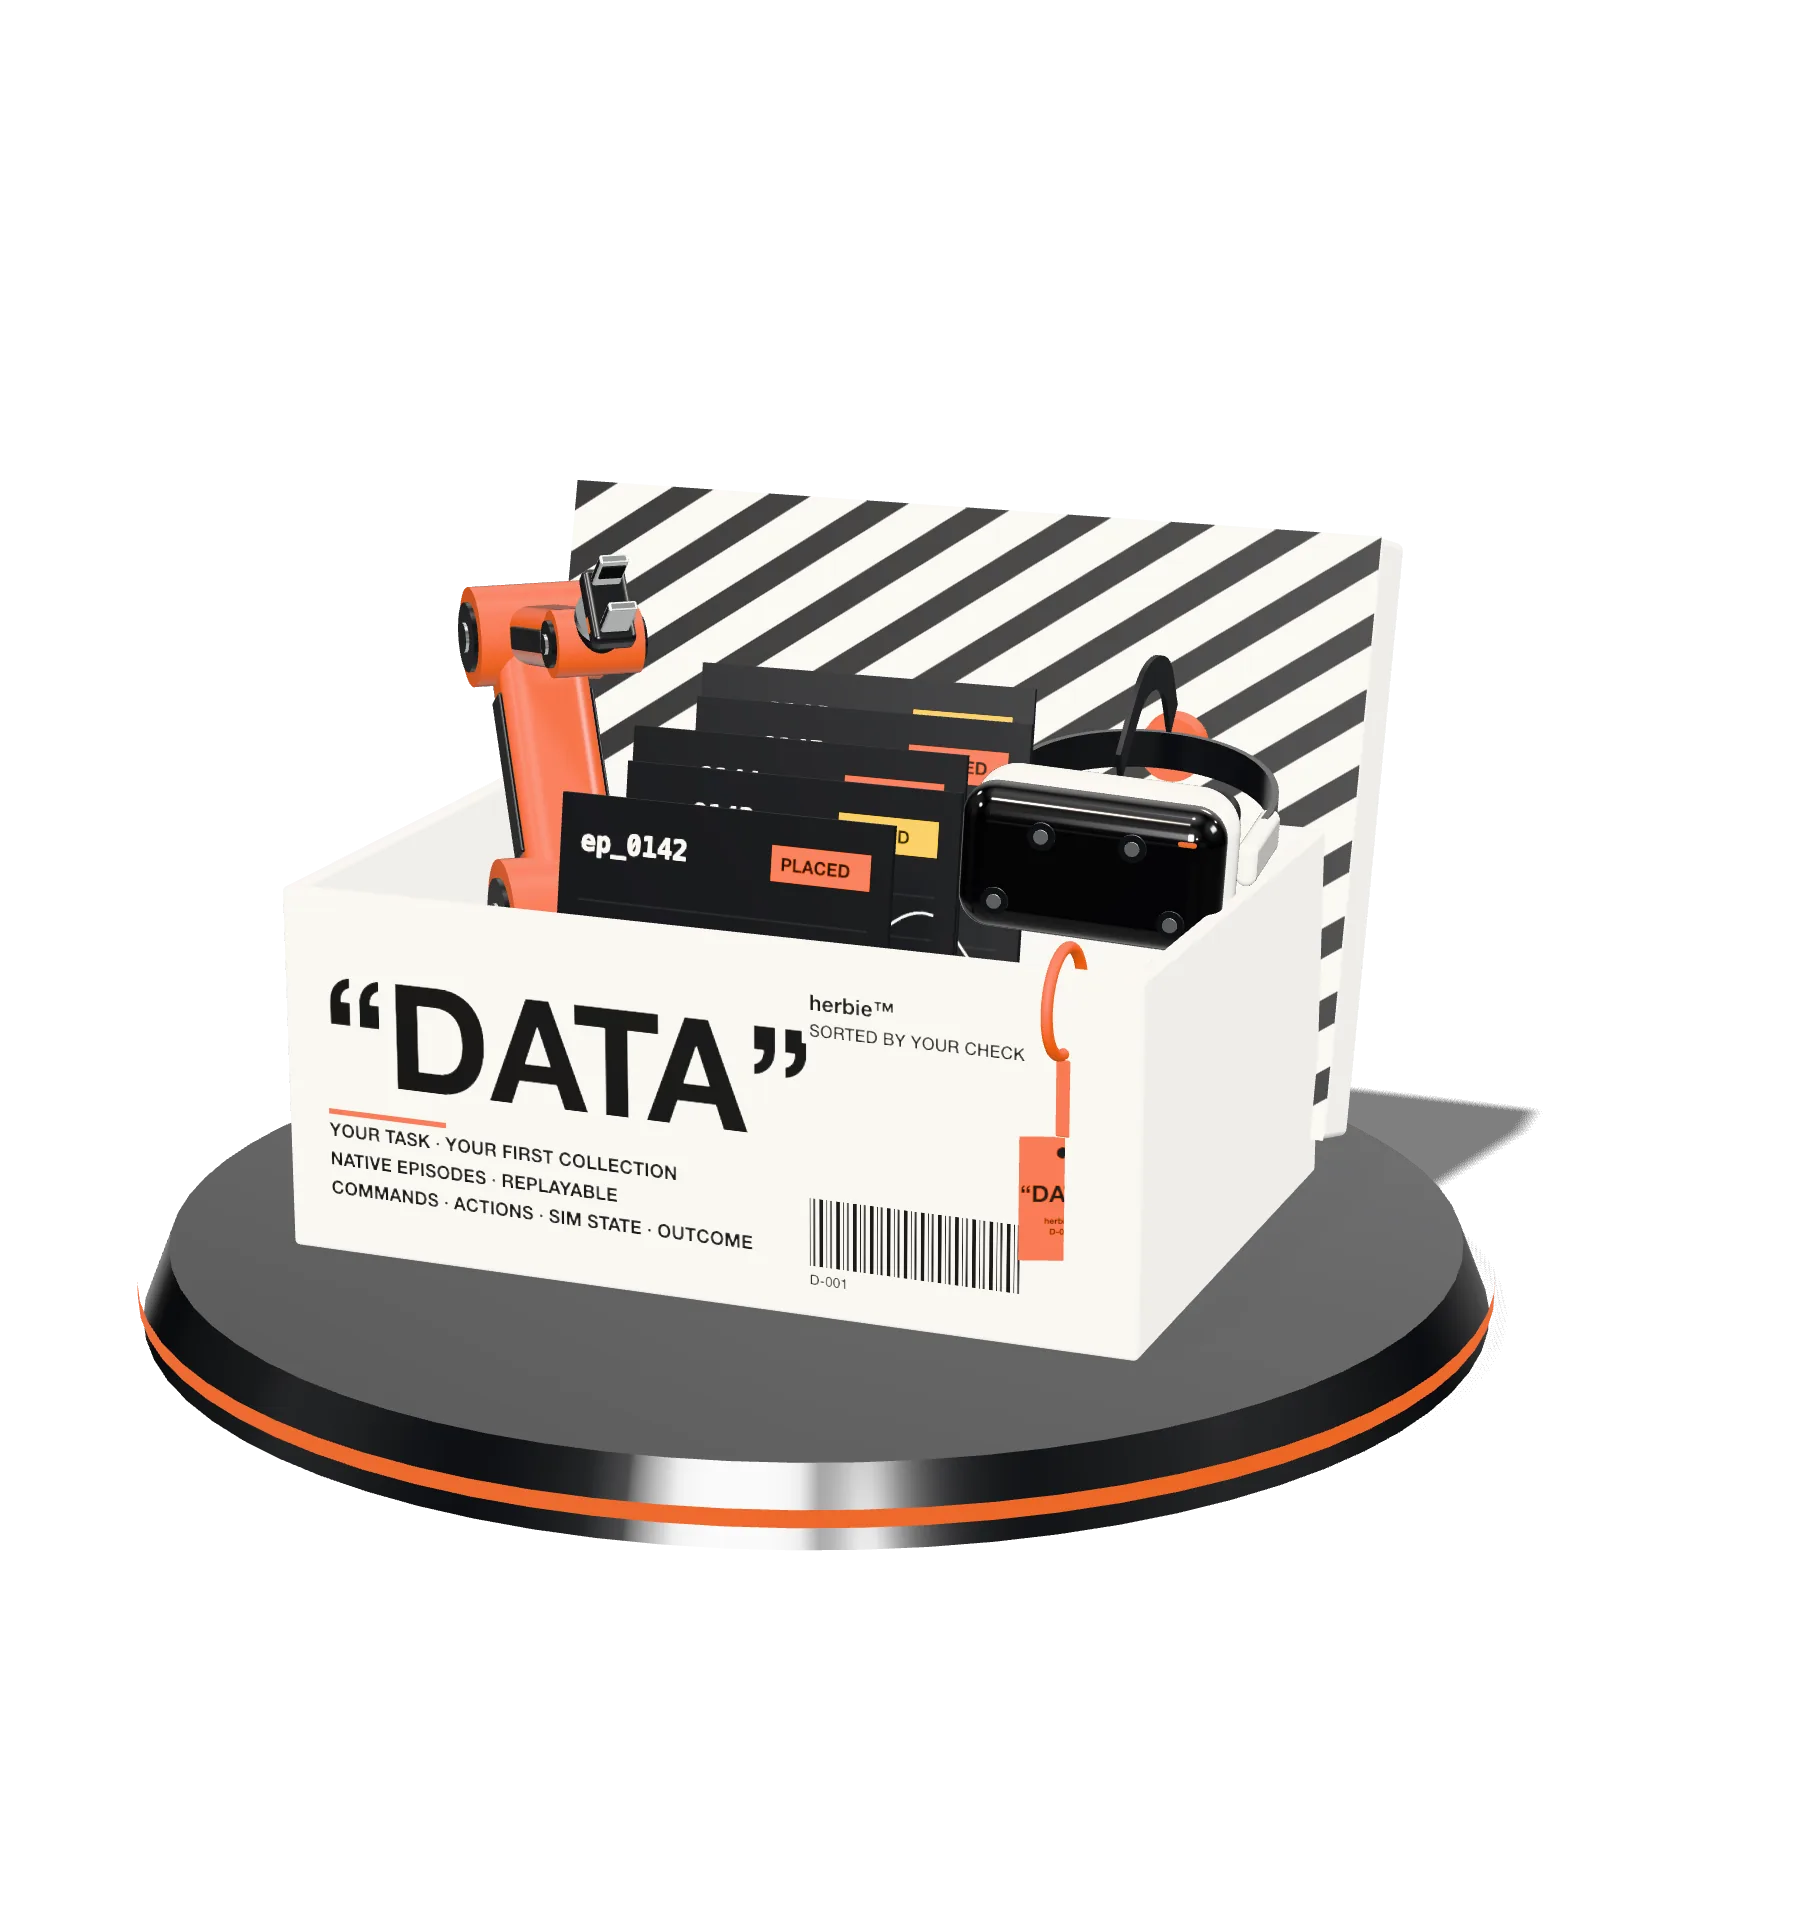 “Your teleop data”